
Internal project
MKIT Robot — Autonomous Delivery Robot
- 15 days
- spec to working mechanical base
- 2,000 m²
- our building, mapped and navigated autonomously
- 100%
- in-house: mechanics, electronics, firmware
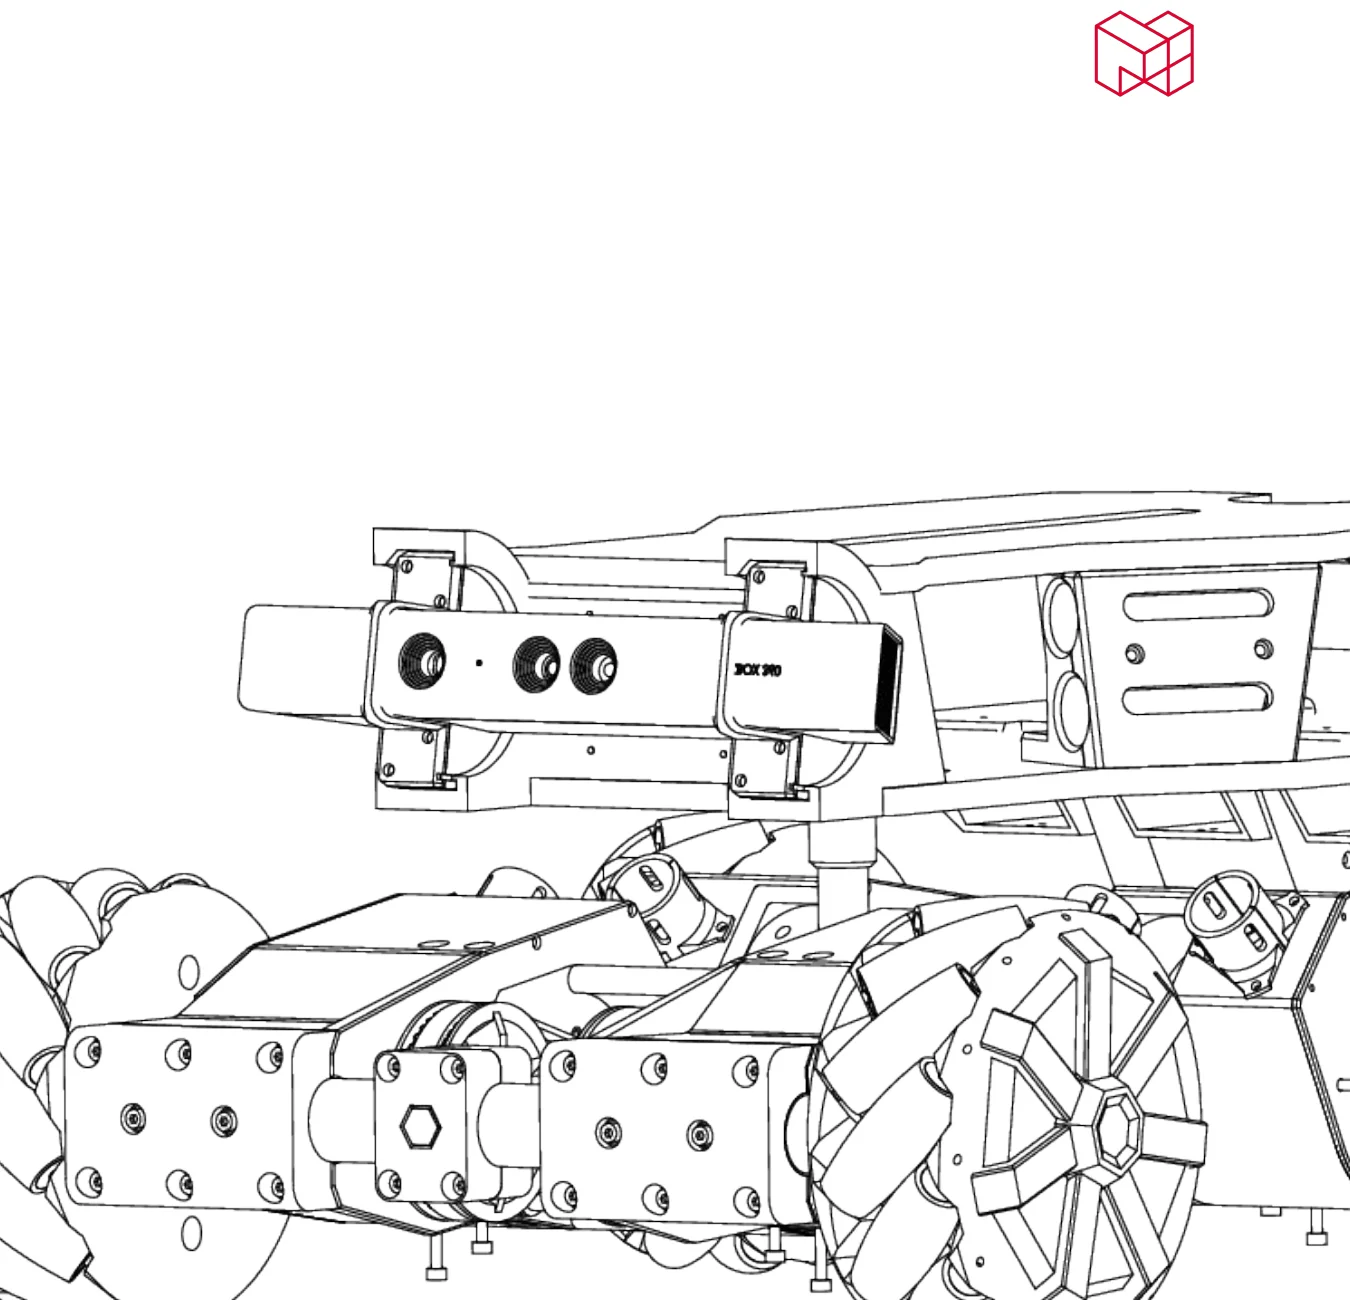
A non-commercial internal project: a functional proof-of-concept built to show clients what's actually behind "a motor and some wheels" — real closed-loop engineering, not a toy.
Every servo was sized and tuned by us in closed loop, precise to the millimetre, with no jerk even at very low speed. Electronics, firmware and mechanics were matched by the same team, and every module was designed in-house so the platform can be reused for other robots.
The MKIT Robot navigating autonomously at the PCI, Techdays 2021.
Project stages
- 01
Goal
Show, not tell: a tangible demonstrator of engineering depth. Anyone can bolt a motor to a wheel — the hard part is closed-loop control precise enough that very low-speed motion has no jerk, with mechanics, electronics and firmware developed together by the same team.
- 02
Approach
We sized and tuned the drive servos ourselves in closed loop, with every module designed in-house so the platform is reusable for future robots. Once the specification was locked, an industrial designer and two engineers designed and prototyped the mechanical base in 15 days.
It runs ROS with 3D LiDAR and SLAM, recognising obstacles and building a live map as it moves. We proved the concept first on a two-Raspberry-Pi cluster to understand the real power budget, then added an onboard PC to scale up.
- 03
Result
The robot autonomously delivers across our own 2,000 m² building at the PCI — recognising obstacles, mapping live, moving precisely even at very low speed. It's on the shelf for now (autonomous mobile robotics is expensive to justify without a paying use case), but it proved the underlying engineering, and the same closed-loop servo and module design already carries over to other robotics work.